
Warehousing and Logistics Solution
From rack to sorting gate, mobile picking and data capture working together
Industry Background
In a warehouse or sorting centre the pain is the number of steps, the frequency of handovers and the need for accurate data.
Repeated picking
Staff move back and forth between racks, totes and the sorting gate.
Records drift from stock
Every pick needs confirming, and a missed or wrong scan pulls the books away from the stock.
Takt times swing
During promotions the pace multiplies, and training temporary staff costs money.
Narrow aisles, shared with people
Rack spacing is tight and staff work the same aisles as the equipment.
Solution Overview
The Mobile Manipulation Robot pairs a modular chassis with a 6-axis collaborative arm for mobile picking and sorting assistance: 5 kg rated and 8 kg peak payload with a working radius of about 900 mm, with the arm, gripper and vision chosen per project and connected to warehouse and order systems.
The Industrial Scanner captures data and confirms tasks, with a 5000 mAh swappable battery good for about 12,000 scans and IP67 sealing that survives a 2.0 m drop; the Material Handling Exoskeleton adds assistance where people still lift and load, so machines and people work as one team.
Solution Advantages
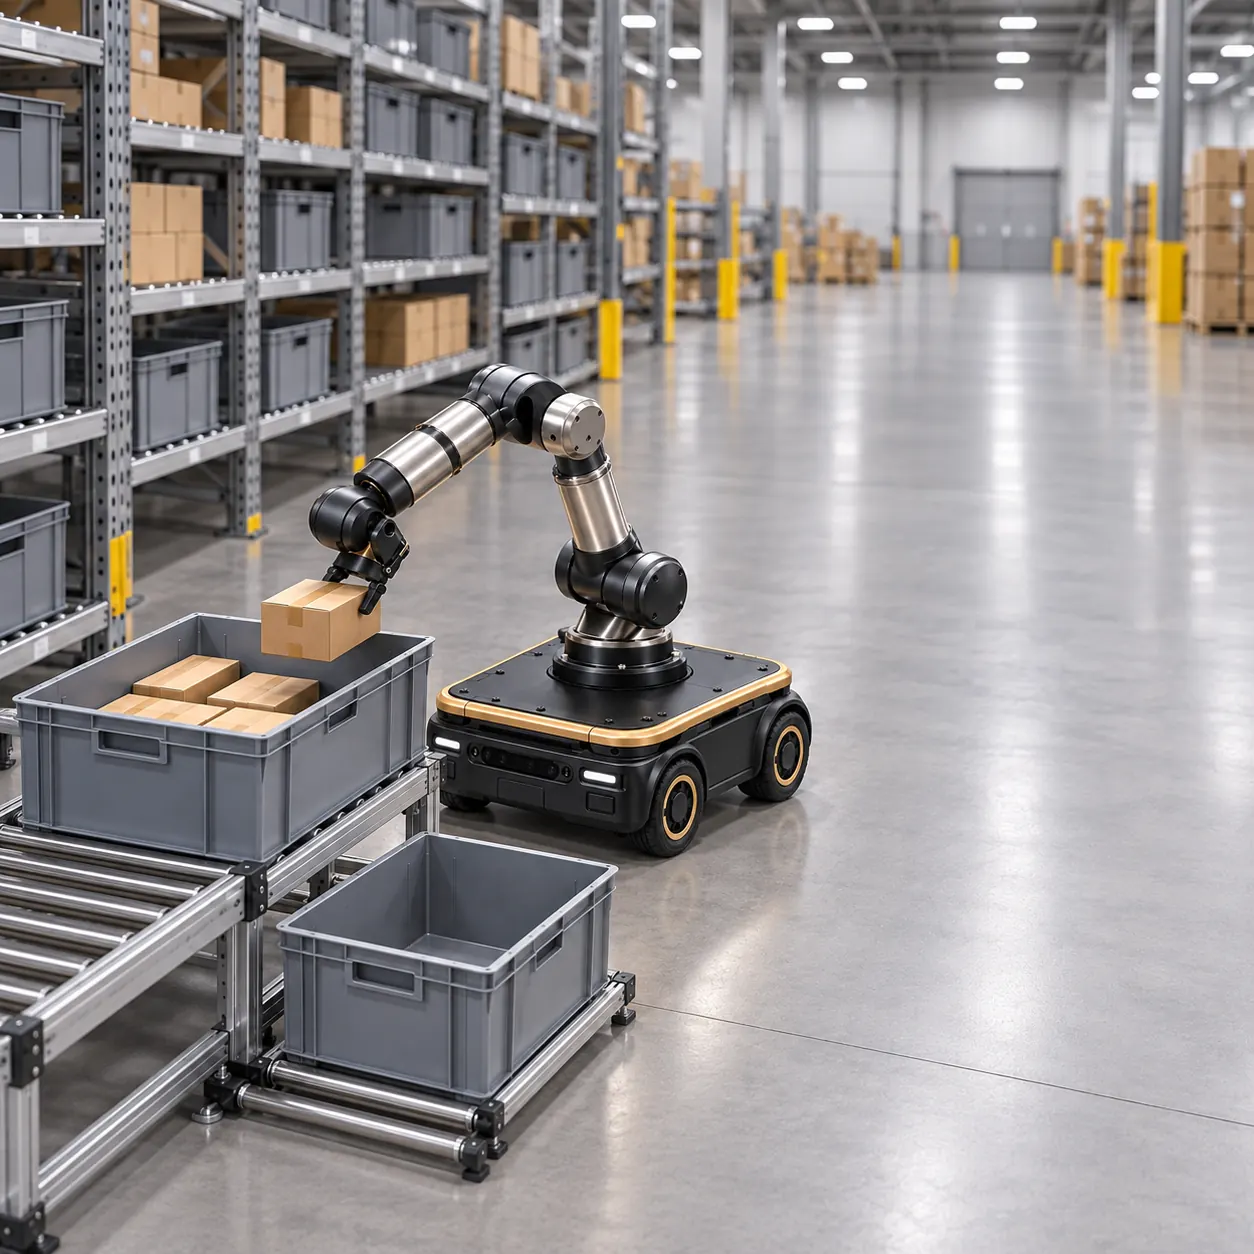
Picking on the move
A modular chassis with a 6-axis collaborative arm: 5 kg rated, 8 kg peak, about 900 mm reach.
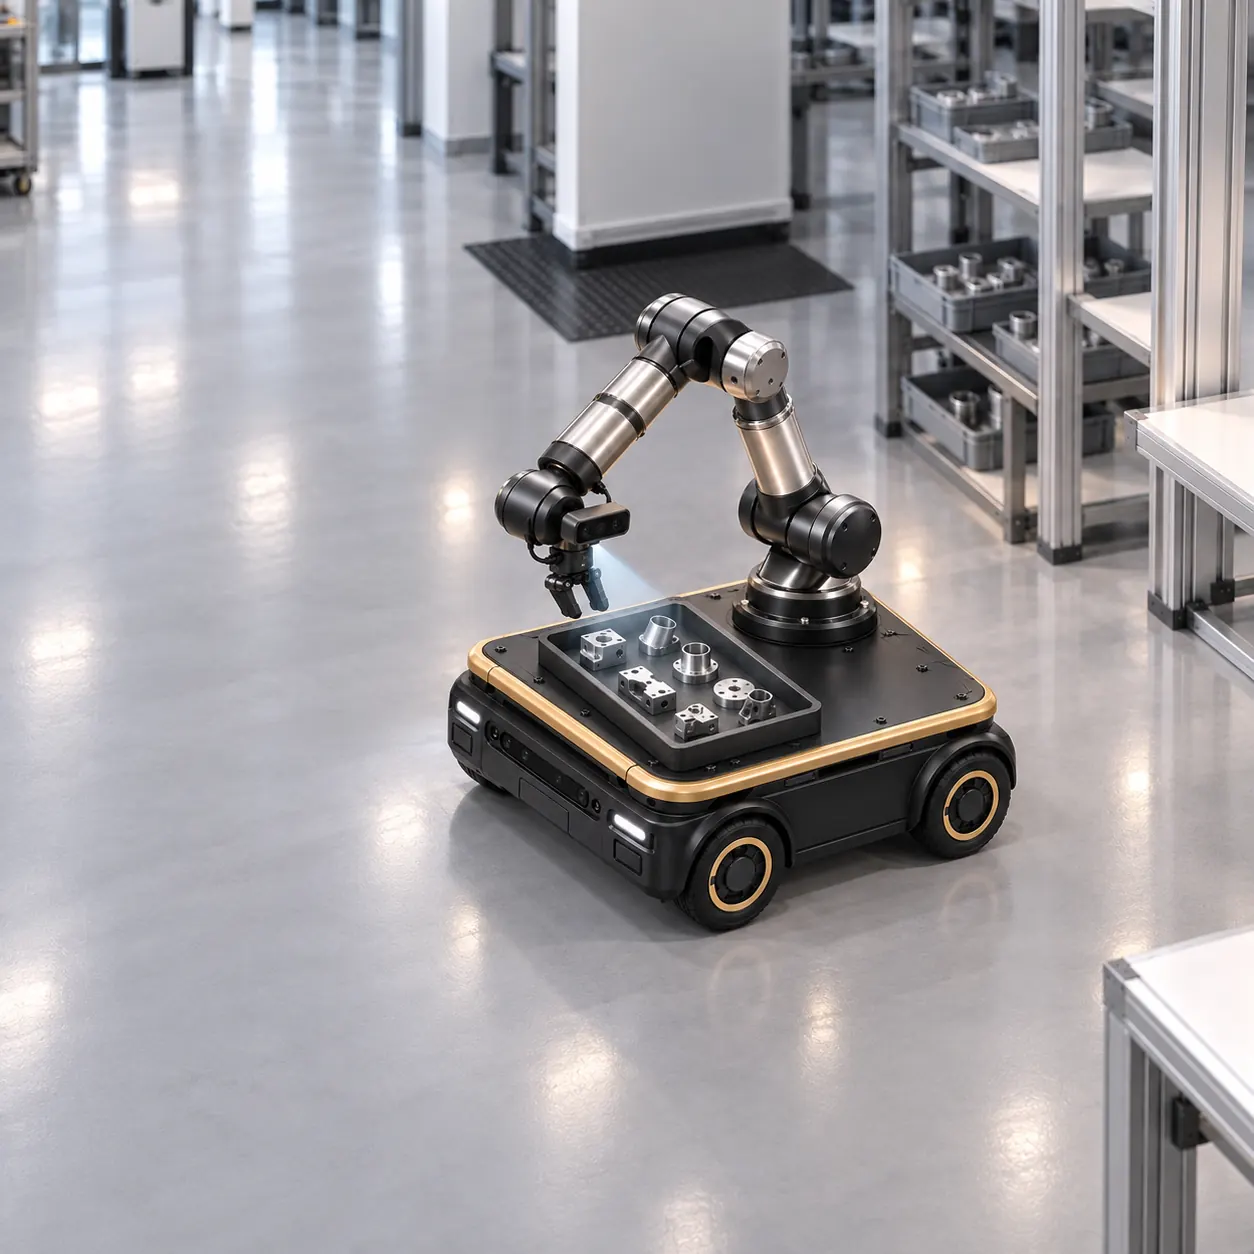
Vision that steadies the grasp
RGB-D vision with pose recognition copes with items that are not neatly placed.
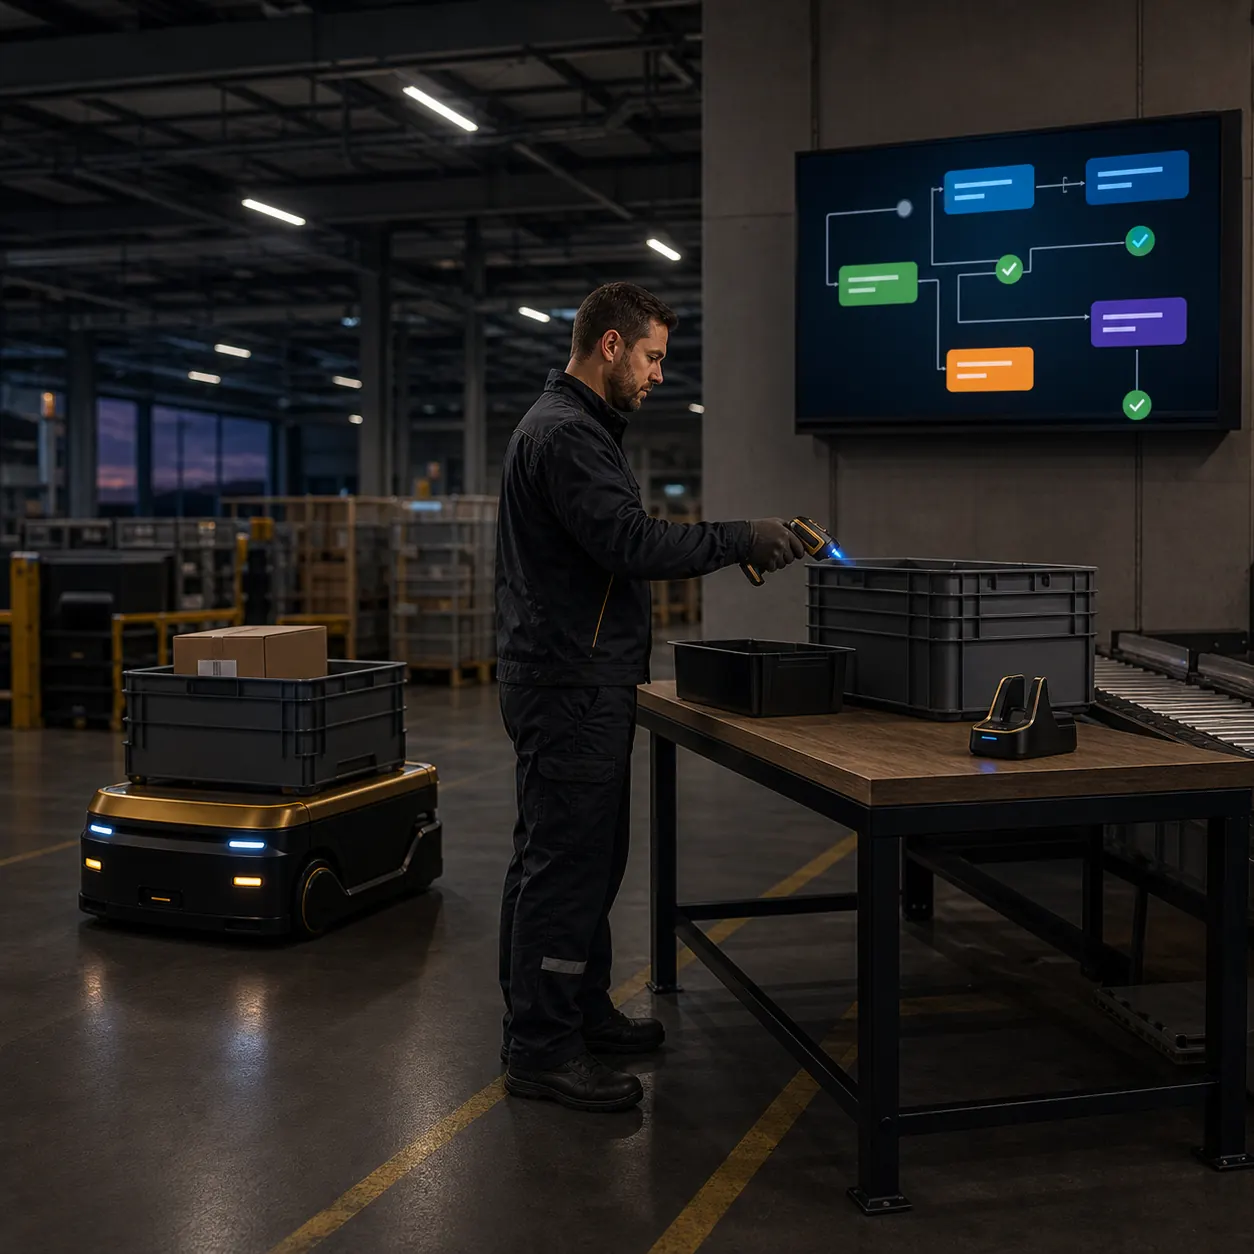
Data capture that matches the stock
1D, 2D and damaged codes are read to confirm inbound and outbound movements in the system.
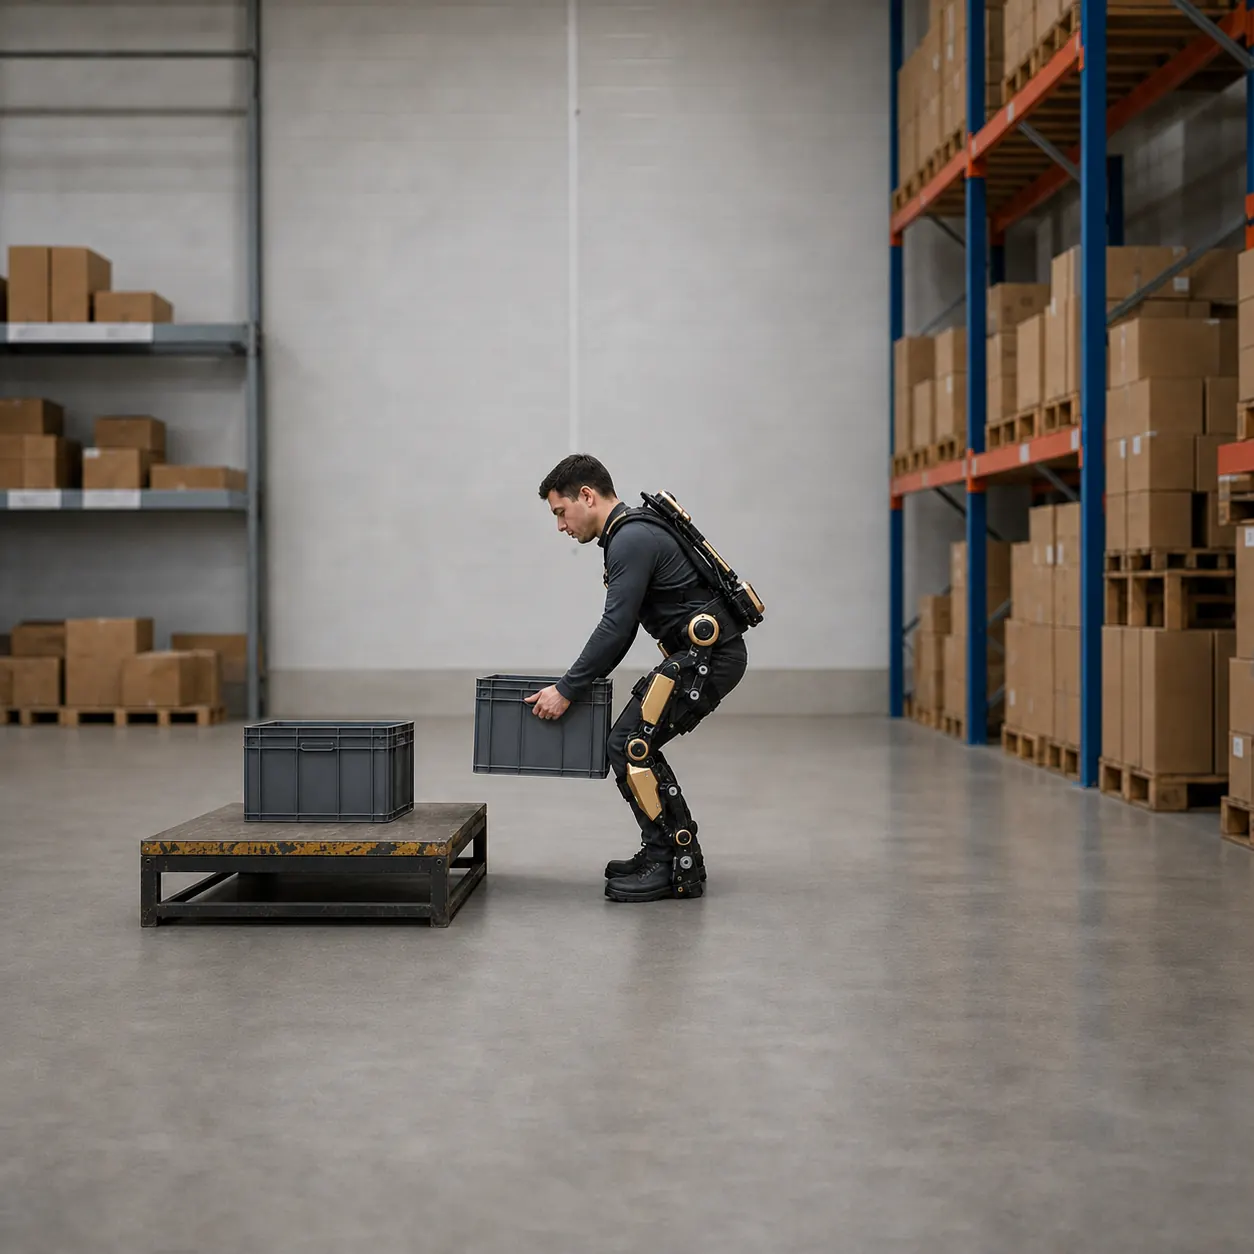
Exoskeleton support where people still lift
Hip and back assistance with several levels.
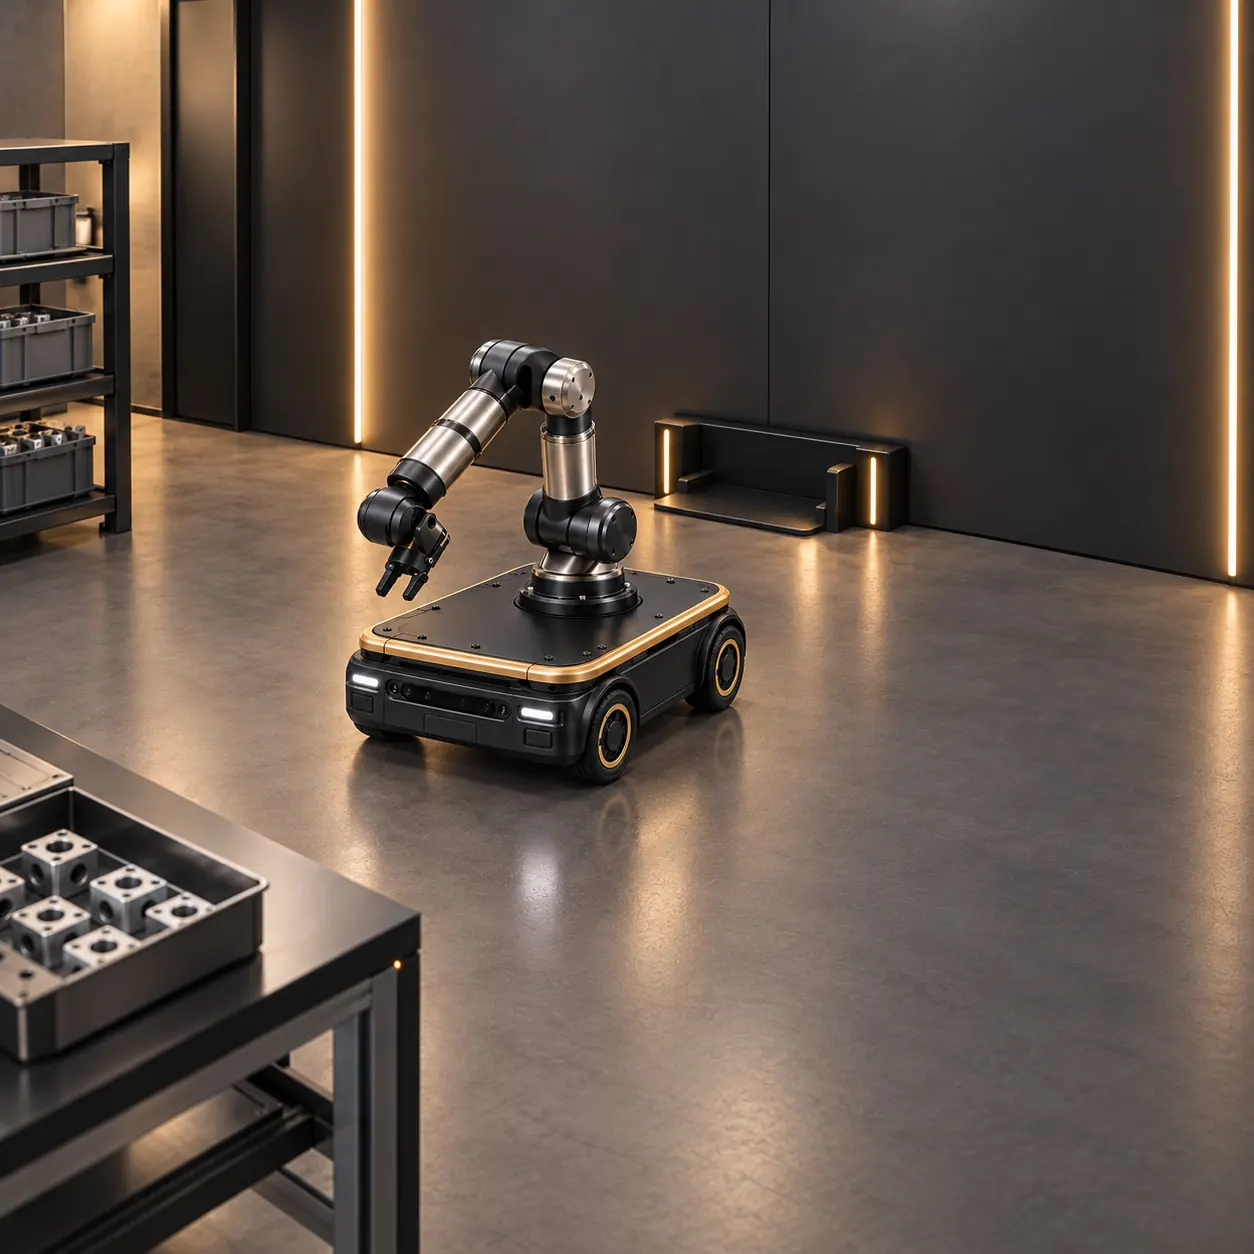
Charges and resumes
It returns to its dock when low and picks up the unfinished task afterwards.
Where It Fits and How It Is Deployed
Typical tasks
Tote and single-item sorting, line-side delivery, inbound and outbound confirmation, loading and manual handling assistance.
How it is deployed
Routes sized to aisle widths and rack spacing, handover points at the sorting gate and buffers, and charging near the work area.
System integration
WMS, order and scheduling systems, with the arm and gripper selected to suit the items handled.
Item shapes and takt time decide the arm and gripper, so we will propose a configuration for your layout.